Home / Platforms
Six tools. One simulation. Ten robots
Build in the tool that fits how you work, test in simulation, and run on the FF robots that support your Skill.
Robots
Which tools work on which robot
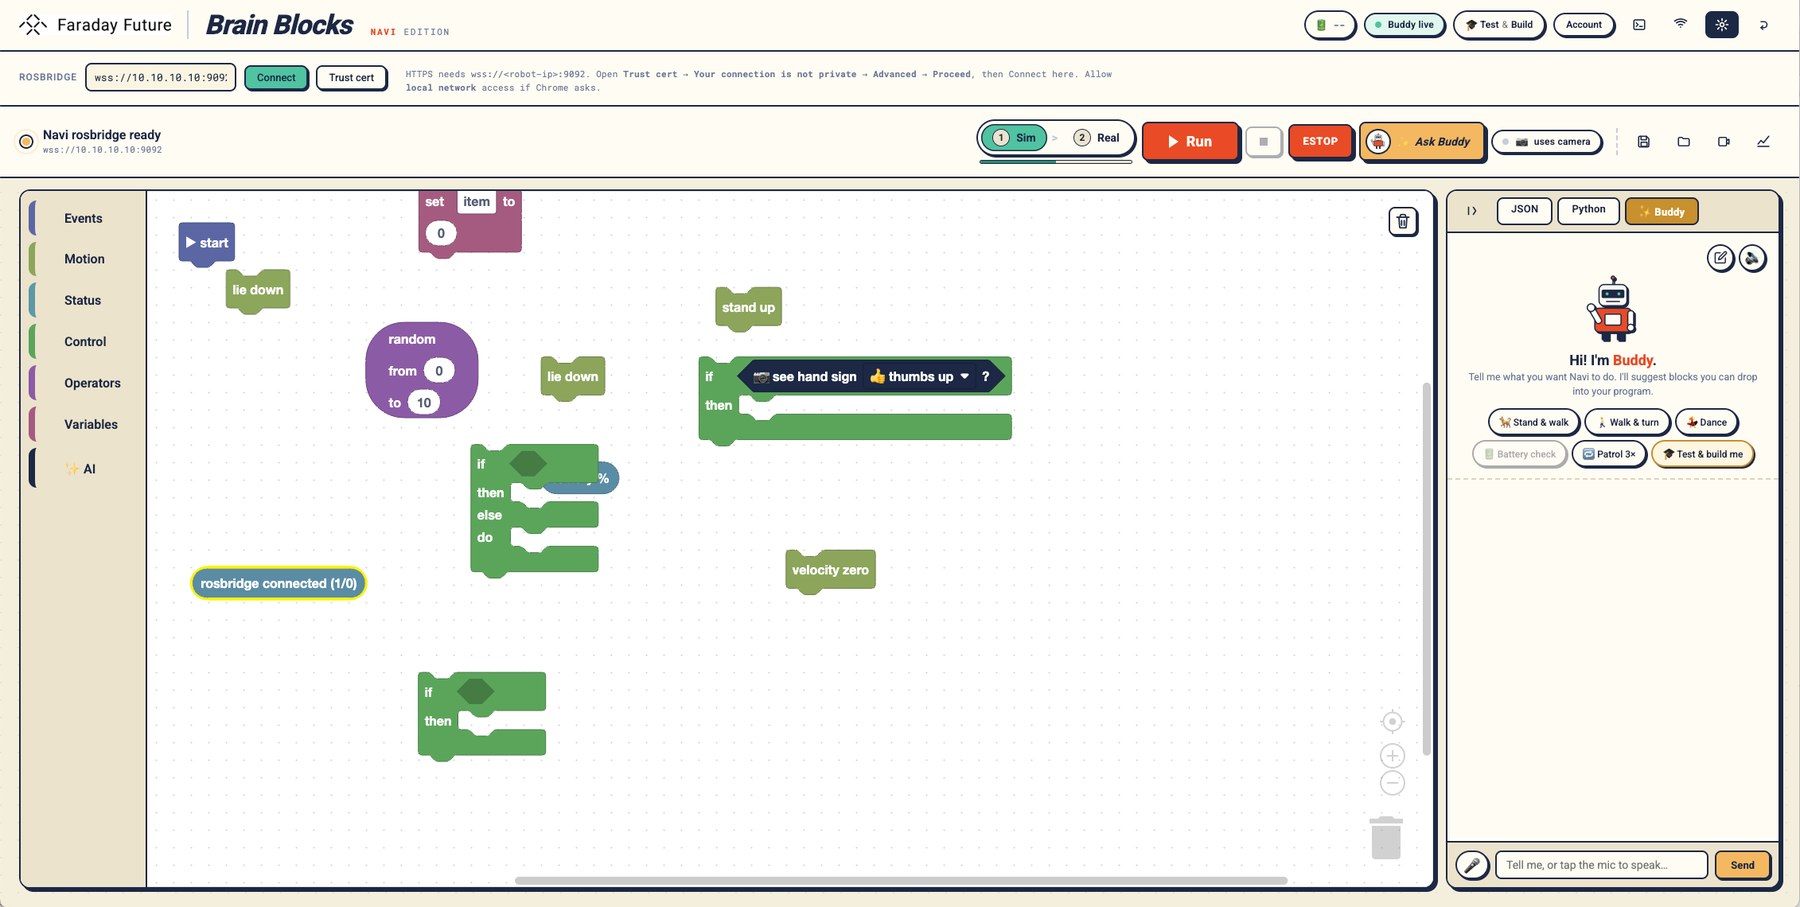
Brain Blocks
Snap blocks. Move a real robot
Scratch-like visual programming for robots, made for classrooms and first-time builders.
- See the Python behind every block
- Publish, download and remix in the community
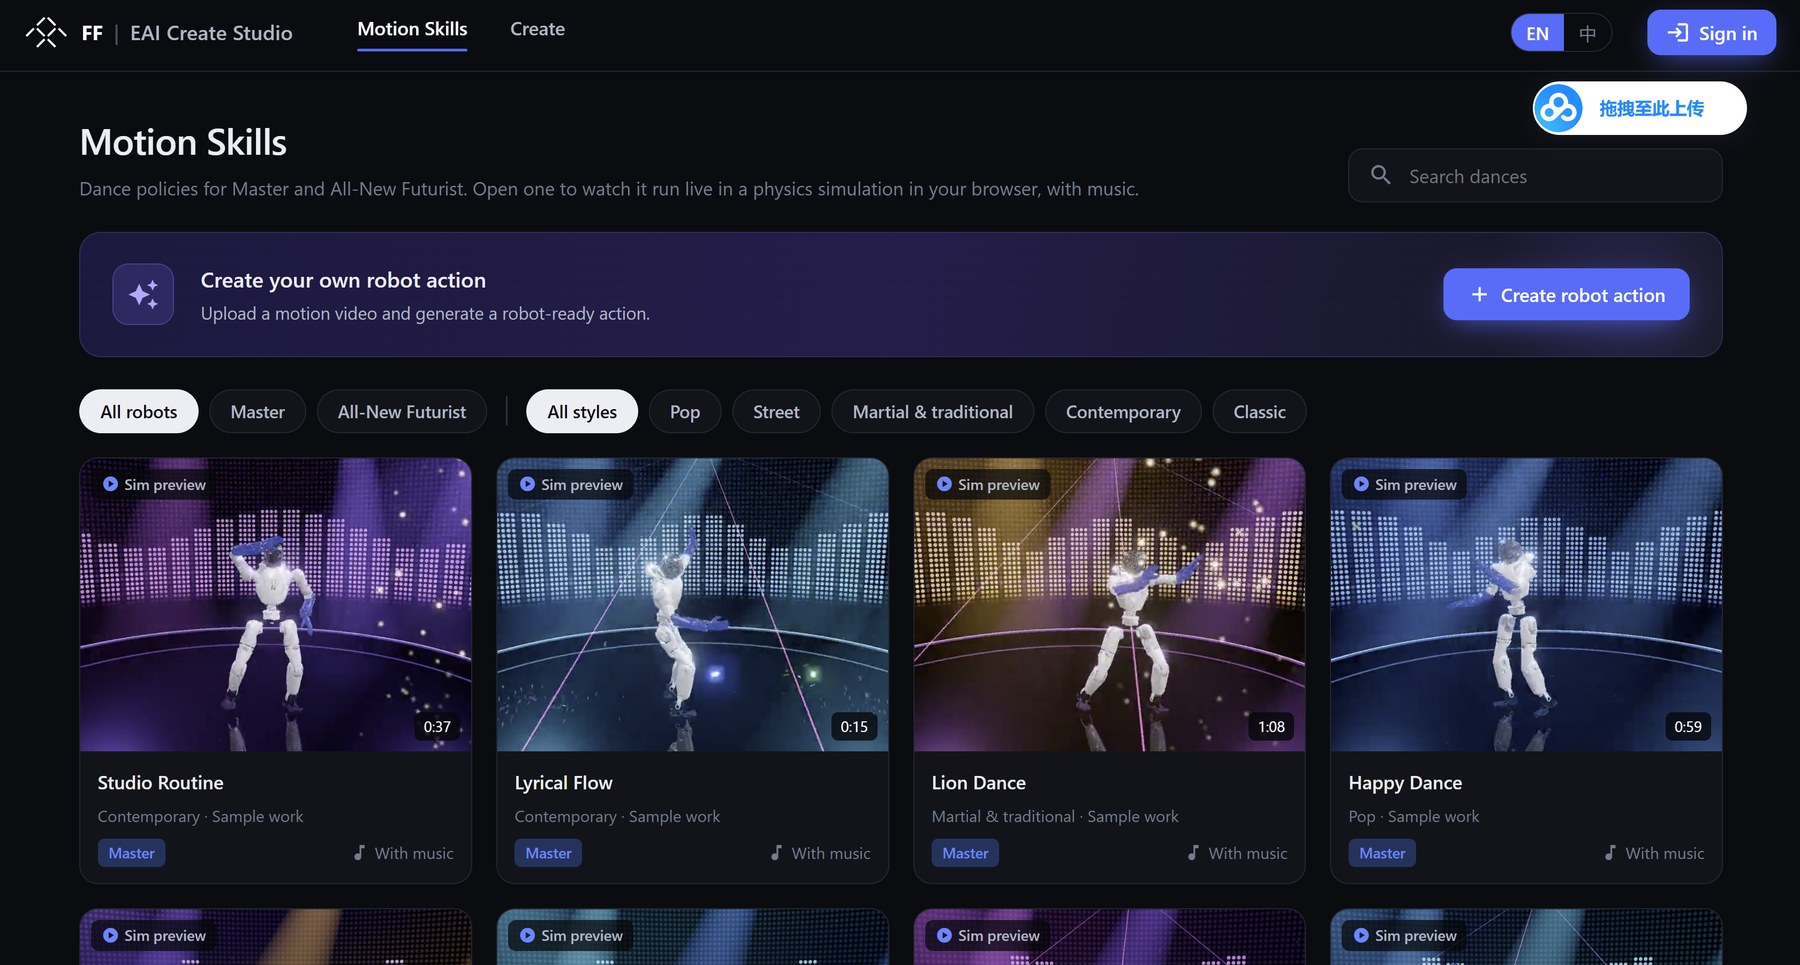
Create Studio
Teach by showing. The robot learns from you
Perform a motion by teleoperation or from video. Create Studio turns the demonstration into a motion Skill.
- Capture from teleoperation or a phone video
- Retarget one motion to different robots
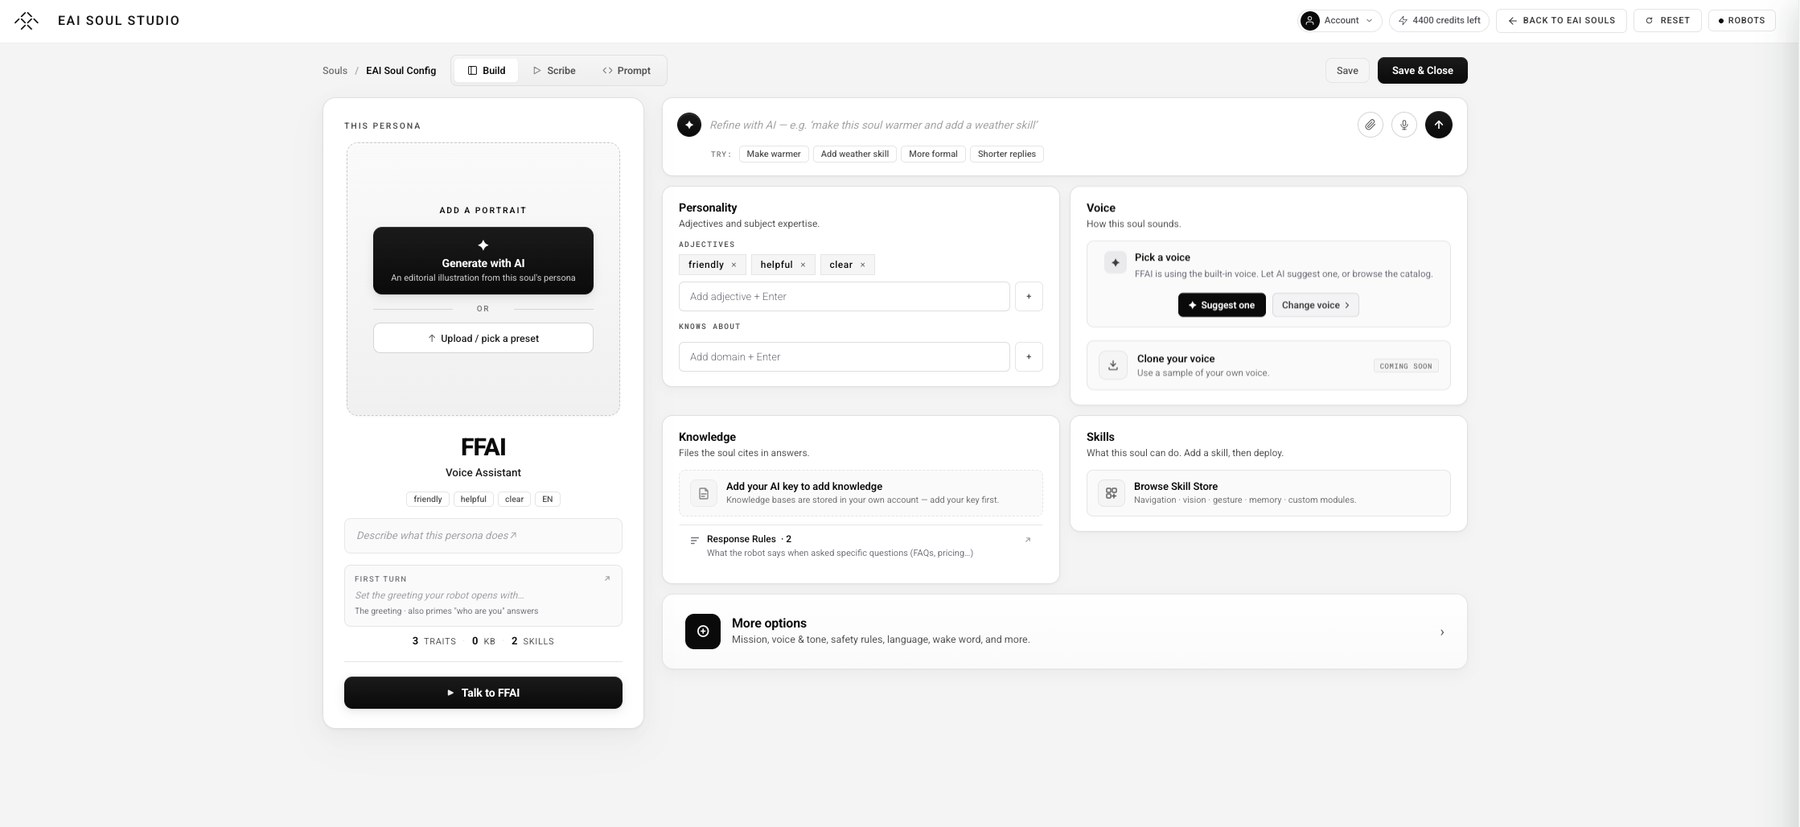
EAI Soul
Give a robot a character
Describe a role, voice, tone and personality in words. EAI Soul turns it into a persona any Skill can use.
- Voice, memory and tone in one file
- Swap characters without retraining
EAI Scribe · Powered by Hermes
The agent that runs every Skill
EAI Scribe is the agent engine on FF robots, built on Hermes. It has no editor to learn: it reads Skills written as SKILL.md files, picks the right one for the moment, and gets better with use.
--- SKILL.md
name: greet-visitor
description: Greet people who wave at the robot
triggers:
  - "someone waves"
  - "a visitor says hello"
---
Walk toward the person, stop one meter away,
say hello in their language, and ask how you can help.
Use the voice and navigation tools.
Load
Skills as plain files
Install Skills from the Skill Store, or write your own SKILL.md. Skills built in the other tools plug in the same way.
Run
The agent picks and acts
From what the robot sees and hears, Hermes chooses the right Skill and calls the robot’s motion, voice and vision tools.
Learn
Better with every run
Memory carries across sessions, and Skills are refined from experience. Test it all in simulation first.
| Run | Policy | Status |
|---|---|---|
| nova-walk-v3 | Imitation → RL | Running |
| nova-wave-v2 | Imitation | Passed |
| aegis-patrol-v1 | RL | Queued |
EAI Studio
Collect, train, test, deploy
The full learning pipeline in one place, with imitation learning and reinforcement learning built in.
- Dataset management and labeling
- Train in the cloud, evaluate in simulation
- One-click deploy to supported robots
1from ff_robot import Robot, Vision
2
3robot = Robot.connect("sim://nova")
4vision = Vision(robot.camera)
5
6for person in vision.people():
7    if person.waving:
8        robot.walk_to(person, stop=1.0)
9        robot.arm("right").play("wave")
10       robot.say("Hello from FF.")
SDK · API
Every motor. Every sensor
Low-level control in Python or C++ for professional-grade Skills.
- Python and C++ SDKs, ROS 2 bridge
- REST API for fleet and Skill management
- ONNX model export
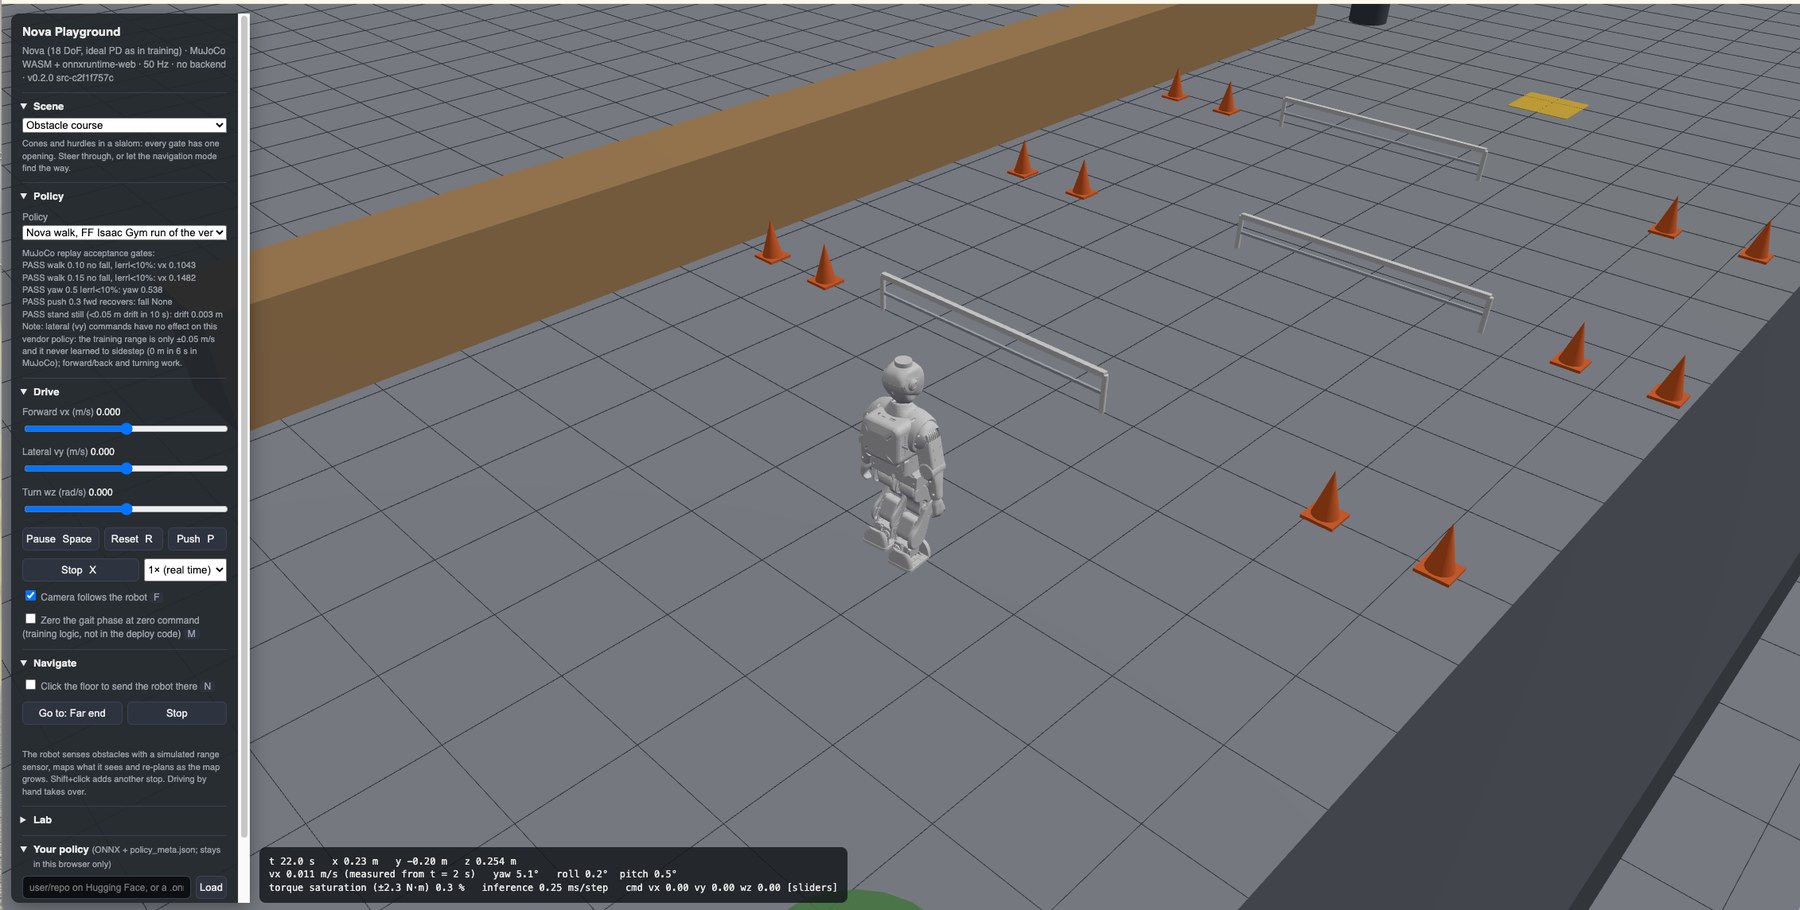
Simulation · Environment
One place to test every tool’s output
Physics-accurate digital twins of FF robots. Whatever you build in the six tools, validate it here before it touches hardware.
- Thousands of runs in parallel
- Scenes for homes, offices, campuses and factories
- The same Skill moves to the real robot